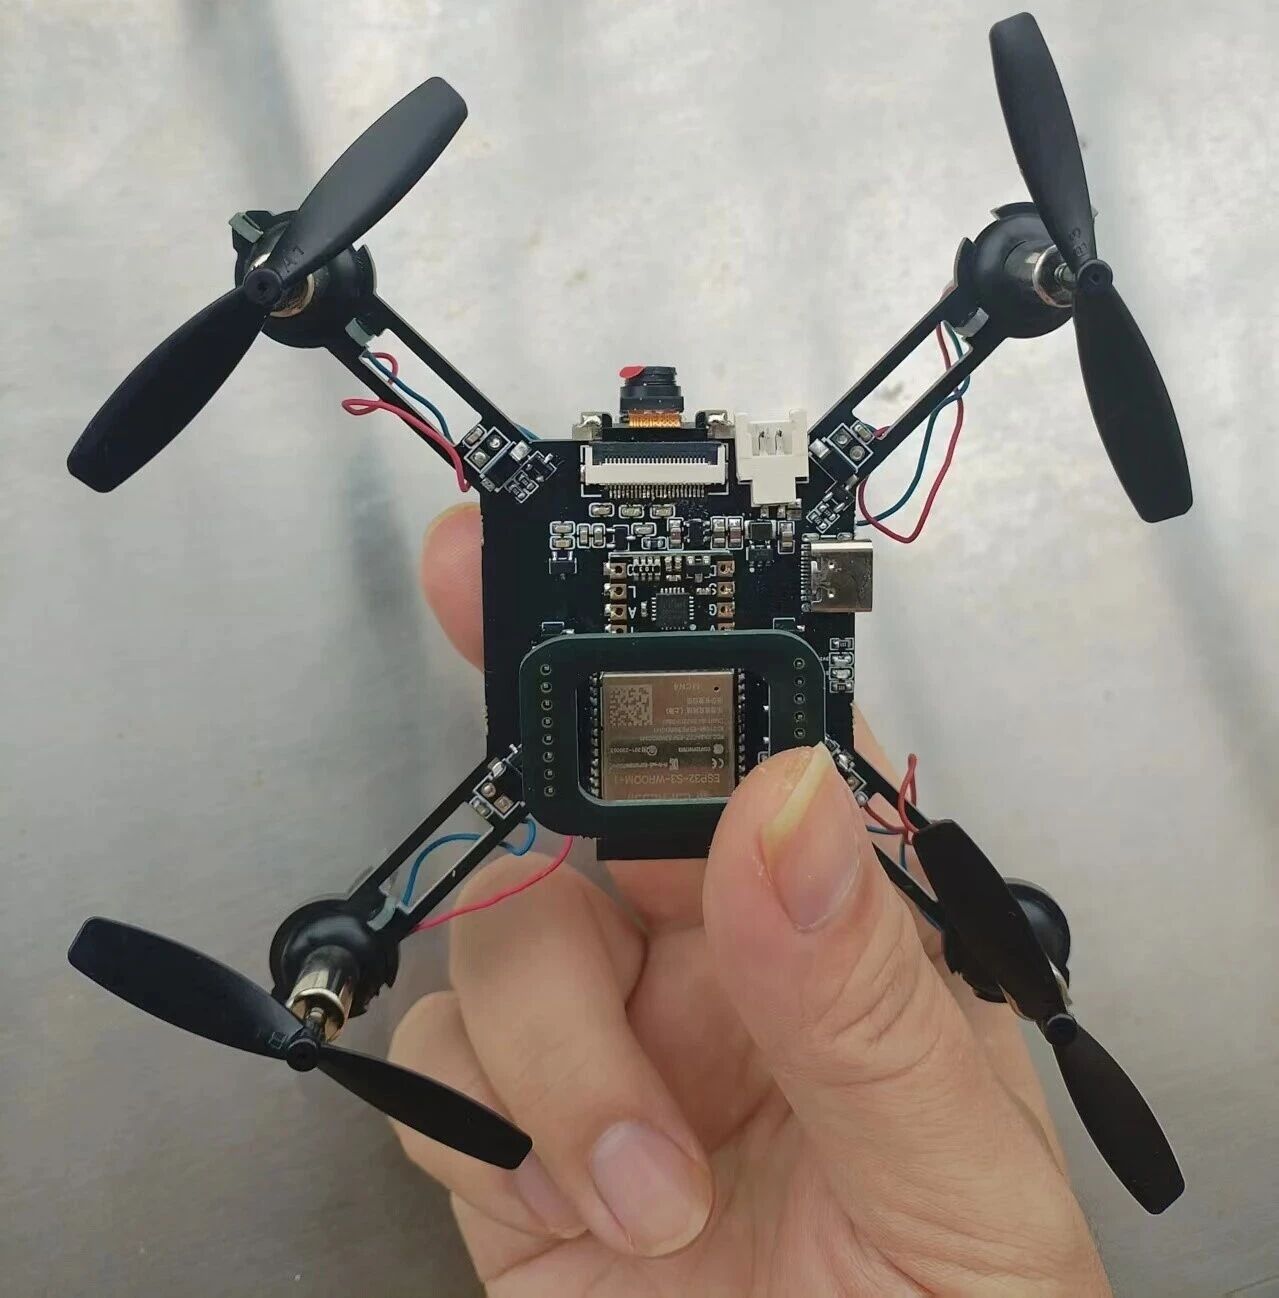
Porting a Quadcopter Attitude Controller to MWORKS
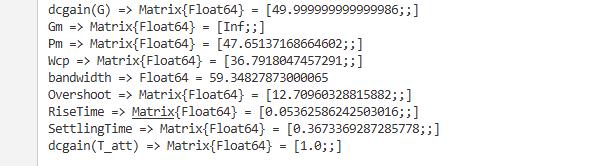
Porting a quadcopter attitude controller from MATLAB to MWORKS: what changes, what does not, and why 1 ms fixed-step PID gains need no retuning.
Porting a Quadcopter Attitude Controller to MWORKS Read More »