Key Takeaways
- ODrive is an open-source brushless motor controller with both hardware and software released openly.
- Its Hackaday.io page has 1,111 skulls, 7,677 followers, 226,000 views, 186 comments, and 32 development logs.
- The project was a 2016 Hackaday Prize entry and has been sustained over multiple years.
- It turns cheap RC-grade BLDC motors into closed-loop servos for robots and robot arms.
- It targets industrial servo performance, not toy-grade ESC behavior.
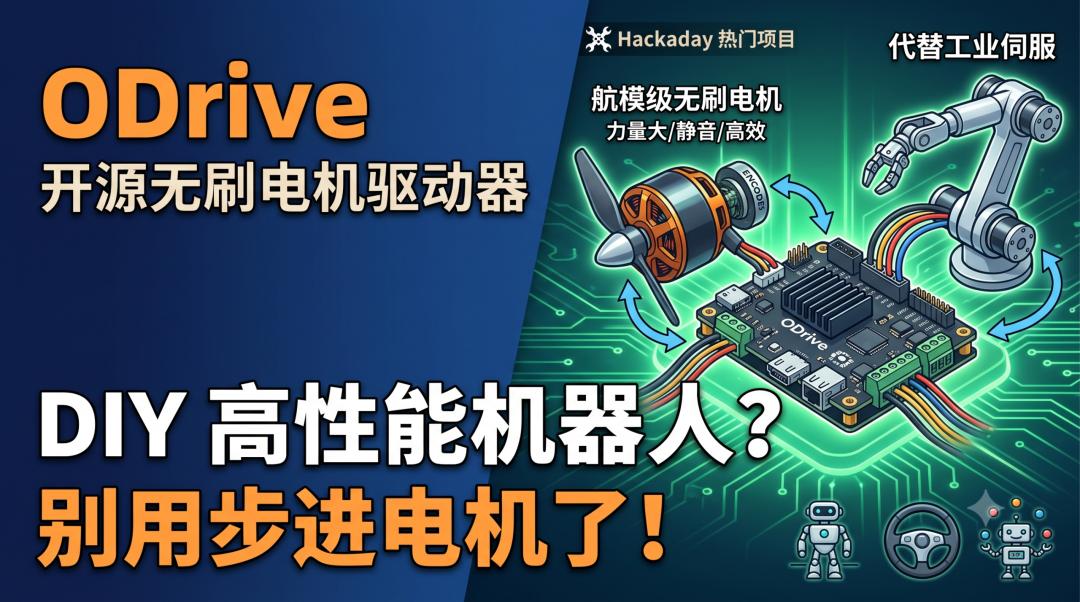
The ODrive brushless motor controller is an open-source project that lets makers drive cheap RC-grade BLDC motors as closed-loop servos. As of 2026, its Hackaday.io page has collected 1,111 skulls, 7,677 followers, and 226,000 views across 32 development logs. The project targets industrial servo performance — high power, low noise, and no step loss — at maker prices.
What Is ODrive?
ODrive is an open-source, high-performance brushless motor controller project with both hardware and software released openly. The goal is straightforward: let makers use inexpensive RC-grade brushless motors to build robots, robot arms, and automation equipment.
Anyone who works on DIY hardware knows the default answer has been the stepper motor. 3D printers, CNC machines, desktop robot arms, and juggling robots almost all use one. Industry moved on long ago to servo-grade brushless (BLDC) motors, which deliver more torque, run quietly, work efficiently, and never lose steps. The open question was why so few people put cheap, powerful RC brushless motors into robots. The author’s answer is blunt: there was no good open-source driver, so the project built one.
Why ODrive Stands Out
The numbers make the case. On Hackaday.io the project has 1,111 skulls, 7,677 followers, 226,000 views, 186 comments, and 32 development logs. It was also a 2016 Hackaday Prize entry — not a weekend experiment, but a serious open-source hardware project sustained over multiple years.
Three Features That Matter
- Closed-loop servo control for RC-grade BLDC motors. The project README states it plainly: RC brushless motors are cheap and powerful, and paired with inexpensive drive electronics they are more than good enough for robots. ODrive is the missing link between the two.
- Hardware and software both fully open source. The author explicitly releases the work as open source in both hardware and software and welcomes contributors. You can reproduce the board, modify the firmware, and run your own control algorithms.
- Industrial servo performance as the target. The project tags list high power, servo, motor control, and robotics. This is not a toy-grade ESC — it is aimed at replacing industrial servos.
Stepper vs Servo: Why Makers Switch
| Aspect | Stepper motor | Industrial servo (BLDC) | RC BLDC + ODrive |
|---|---|---|---|
| Torque | Low | High | High — RC motors are cheap and powerful |
| Noise | High | Low | Low |
| Step loss | Yes | No (closed loop) | No (closed loop) |
| Cost and ecosystem | Cheap and everywhere in 3D printers and CNC | Expensive and closed | Motors are cheap; ODrive hardware and firmware are open source |
Getting Started With ODrive
The project is hosted on Hackaday.io. The README summary does not include build or flash commands, so below is the confirmed minimum path rather than guesswork.
- Open the project page at hackaday.io/project/11583-odrive-high-performance-motor-control.
- Follow the GitHub repositories linked from that page — the hardware schematics, PCB files, and firmware source are kept separately.
- Prepare the hardware: one or two RC-grade BLDC motors, an encoder for closed-loop feedback, an ODrive board (self-fabricated or a later commercial version), and a DC power supply.
What to expect: after reading the 32 development logs you will have a clear picture of the hardware iteration path, the control-algorithm choices, and the host tuning interface — enough to decide whether to fabricate your own board or buy a finished one.
Pitfalls to Avoid
- Brushless motor drive involves high current, bus capacitors, and back-EMF. It is far more dangerous than blinking an Arduino LED — always current-limit the first power-up.
- The encoder and the motor phase sequence must be aligned together. The first successful run usually takes several hours of tuning.
- The README is an introductory article. For wiring, firmware flashing, and Python host commands, follow the GitHub repository documentation rather than copying commands from a summary.
What You Can Build
- Desktop robot arm: a pair of BLDC motors plus ODrive can replace a traditional servo or stepper setup for a two-axis or multi-axis arm, with a step change in torque and smoothness.
- Balancing robot or two-wheel self-balancing cart: direct-drive BLDC wheels respond faster and deliver more torque than stepper or geared motors.
- Force-feedback steering wheel or joystick: a closed-loop BLDC is an ideal fit for force feedback.
- Juggling robot: the README specifically calls out the juggling-robot scenario — high dynamics and low noise, exactly where BLDC beats steppers.
- Replacing 3D printer steppers: theoretically possible, but it requires rewriting the kinematics, so treat it as an advanced challenge.
Who ODrive Is For
- Makers building robot arms, robots, or balancing vehicles who are held back by stepper performance.
- Hands-on engineers with embedded experience who can tune parameters, read waveforms, and work with closed-loop control.
- Engineers interested in the open-source hardware ecosystem who are willing to read schematics and modify firmware.
- Not for absolute beginners — BLDC drive is a high-voltage project with real risk. If you are starting from an Arduino LED, build your motor-control fundamentals first.
Project Links
- Hackaday.io project: https://hackaday.io/project/11583-odrive-high-performance-motor-control
Have questions about this article? Feel free to contact us at [email protected] — we’re happy to help!
Frequently Asked Questions
What is ODrive?
ODrive is an open-source, high-performance brushless motor controller with both hardware and software released openly. Its goal is to let makers drive cheap RC-grade BLDC motors as closed-loop servos inside robots, robot arms, and automation equipment.
Is ODrive open source?
Yes. The project is released as open source in both hardware and software, and the author welcomes contributors. That means you can reproduce the board, modify the firmware, and run your own control algorithms on top of it.
What motors does ODrive work with?
ODrive is built to drive RC-grade brushless (BLDC) motors, which are cheap and powerful. Paired with inexpensive drive electronics and an encoder for closed-loop feedback, those hobby motors are good enough for robot joints and motion platforms.
What do I need to get started with ODrive?
You need a BLDC motor, an encoder for closed-loop feedback, an ODrive board that you fabricate or buy, and a DC power supply. Wiring, firmware flashing, and host commands should come from the GitHub repositories linked on the project page.
Is ODrive safe for beginners?
No. Brushless motor drive involves high current, bus capacitors, and back-EMF, so it is far more dangerous than blinking an Arduino LED. Limit current on the first power-up, and expect several hours of tuning to align the encoder and motor phases.
About Aomway
Aomway is a technology company specializing in drone and FPV equipment, publishing in-depth analyses of motor control, embedded hardware, and open-source robotics projects. With over 15 years of industry experience, Aomway covers the full spectrum from flight controllers and FPV goggles to thermal imaging cameras and long-range datalinks for the global drone community.